Maintain the
visual link.
The visual link for UAVs & UGVs.
Built for the moments video breaks.
Semantic stream
Measured prototype result
Software prototype
A smaller stream.
A more resilient picture.
BUILT WITH
INDUSTRIAL CONVICTION
Investor · IVFOS pilot completed
Investor & commercial agreement
Technical endorsement for government proposals
A lost picture.
A platform at risk.
You built a capable machine.
Don't let the video link become its limit.
Electronic warfare and constrained channels can cut off the picture an operator needs. More video compression still leaves the mission dependent on a bandwidth-hungry stream.
Semantic Link is designed to preserve visual context on the bandwidth that remains—helping operators make decisions, recover assets and protect the platform.
Send understanding.
Keep awareness.
Understand the scene onboard. Send its essential geometry, objects and changes. Rebuild a visual view for the operator—without transmitting the full video.
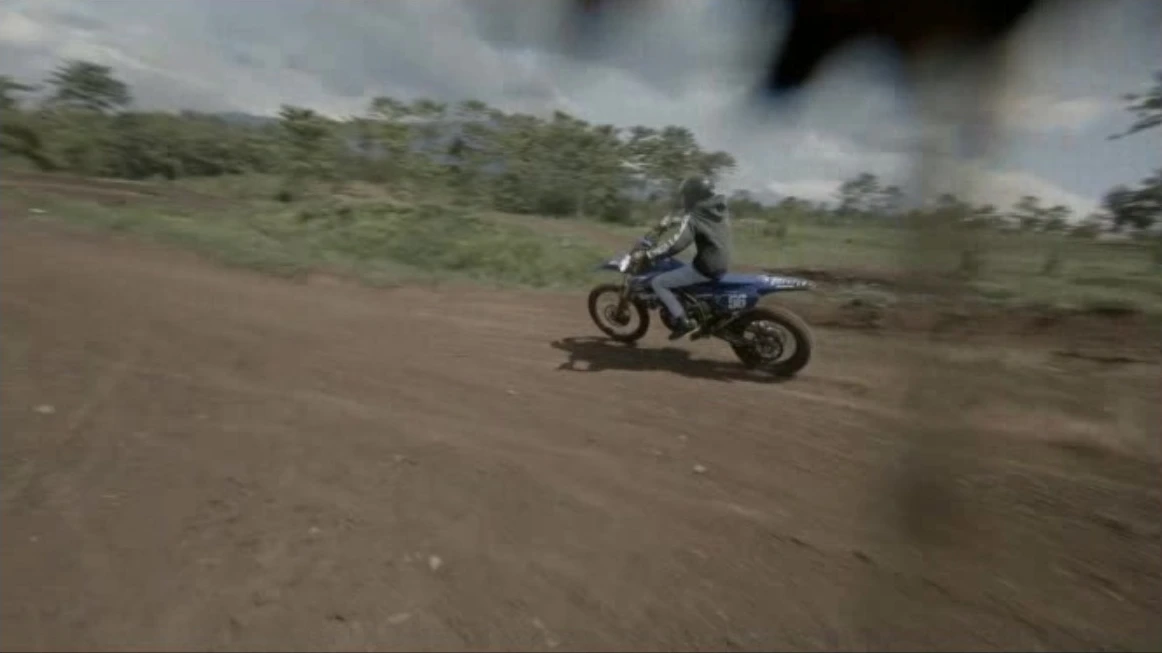 SOURCE / 01
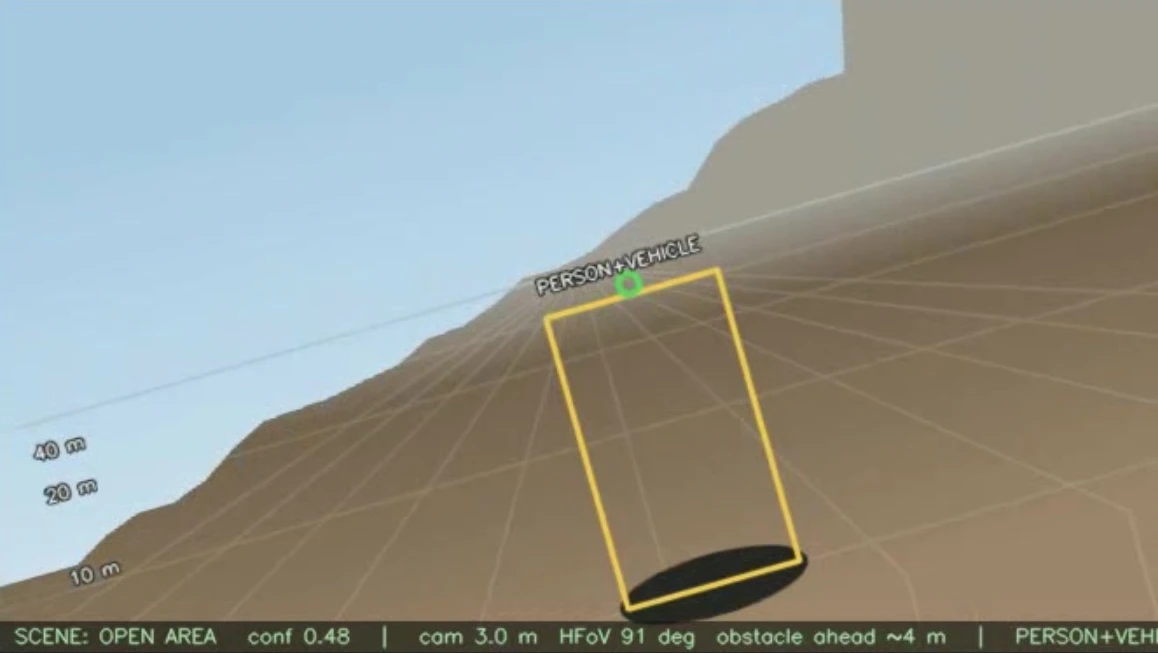 SEMANTIC LINK / 02
The same scene. Camera video stays onboard; the operator view is rebuilt from the semantic stream.
Measured link rate
Per scene update
Scene updates
Actual TRL 4 software output on real-world footage. Embedded integration and flight validation are the next steps.
The scene changes.
That's what we send.
Keep the heavy perception onboard. Transmit a compact description of what matters through the platform's existing radio link.
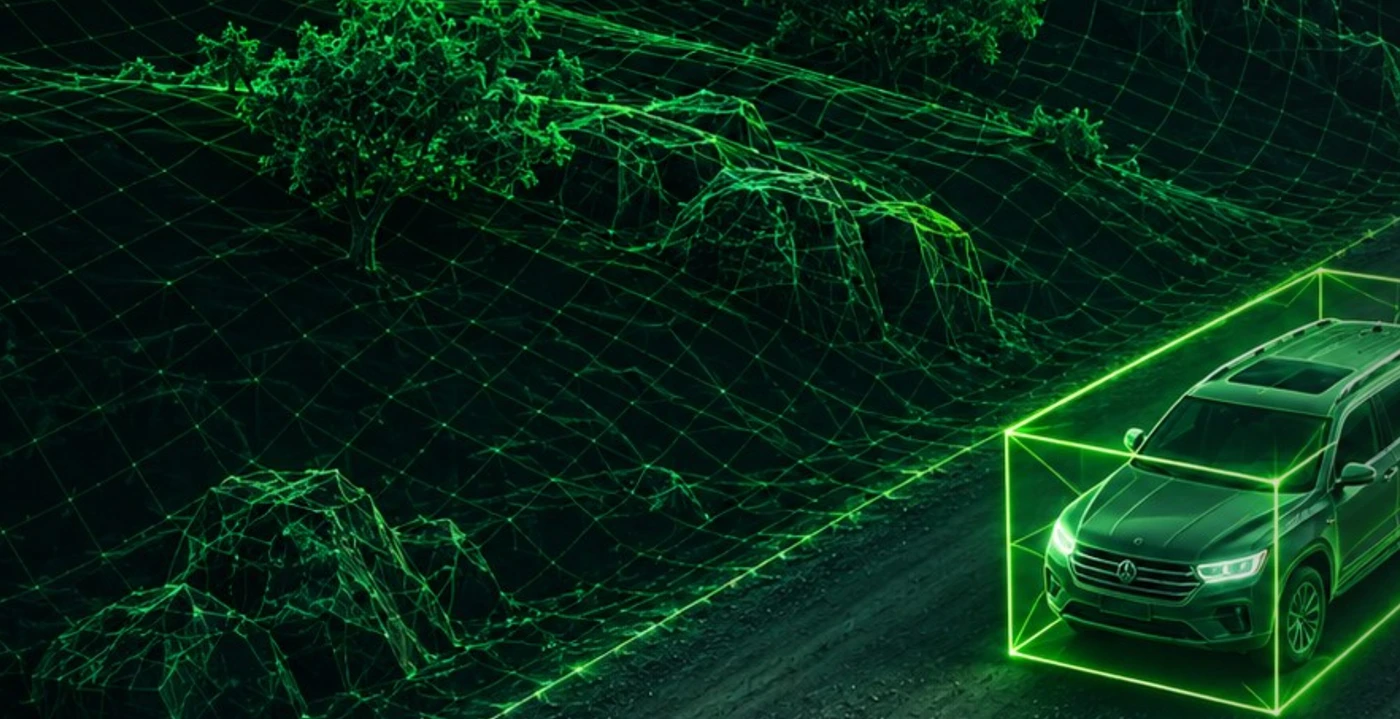 WORLD MODEL / CONCEPT VISUALIZATION
01Scene geometry
Terrain, structures and spatial context. A compact representation gives the operator a view of the environment.
02Detected objects
Mission-relevant vehicles, people and assets—represented as objects rather than entire video frames.
03Meaningful changes
Movement and changes in the scene are prioritized, instead of repeatedly sending every pixel.
04Real camera snapshots
Adaptive, prioritized images complement the reconstructed scene. Image frequency and quality depend on the available link budget.
Camera → scene understanding
Ultra-low-bandwidth stream
Reconstructed visual context
Different platforms.
The same critical link.
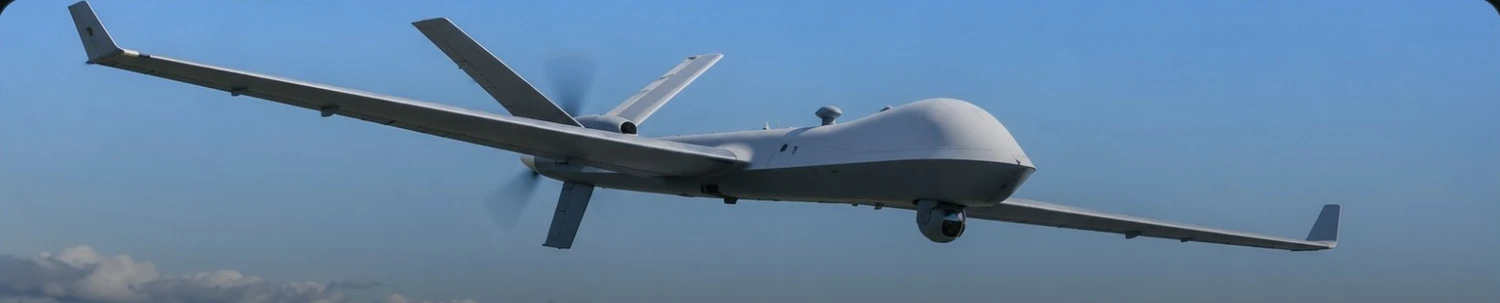 ILLUSTRATIVE APPLICATION
Keep context.
Extend awareness.
Visual situational awareness for reconnaissance platforms operating over long-range and bandwidth-constrained links. Keep mission-relevant context available as conventional video degrades.
Build it in.
Make it yours.
A path from evaluation to platform integration, designed around UAV and UGV manufacturers.
Current stage: TRL 4 software prototype
Embedded integration targetsTECHNICAL BRIEF
or equivalent
These are integration targets from our development plan, not measured specifications of a production module. Total link usage depends on semantic updates, transport overhead and adaptive images.
Hard problems.
Machines that matter.
Computer vision. Autonomy.
Engineering with a purpose.
Unsolved Machines is the U.S. brand of Codective LLC. We build technology for autonomous platforms, with experience spanning visual-inertial navigation, onboard perception and semantic reconstruction.
Our IVFOS navigation pilot with IAI is complete. Semantic Link builds on that engineering foundation, with a focused goal: resilient visual communications that help operators preserve awareness and protect valuable machines.